Object-Size Estimation
with a Wearable Robot Glove
Research on object-size and grasp-force estimation with a wearable robotic glove.
Object-size estimation from actuation signals
In a tendon-driven glove, motors pull wires to assist finger flexion and extension. Object size changes when contact occurs and how far the wires move. This relationship was used to estimate object size from the actuation unit without adding sensors to the wearable glove.
Measurement hardware and actuator control
I developed the wire-tension measurement device, an adjustable-size grasp-force measurement device, and motor control. Tension was measured at the actuation unit, while reference grasp force came from a separate device serving as the grasped object.
Two motors drove glove flexion and extension while encoder and tension signals were collected. An adjustable test object was used to examine how object size relates to actuation state and grasp force.
Contact detection and grasp-force estimation
Motor encoder and wire-tension signals were used to detect hand–object contact and estimate object size. The study examined an estimation pipeline combining LSTM and linear regression, then used estimated size as an input for grasp-force estimation.
Experiments with everyday objects
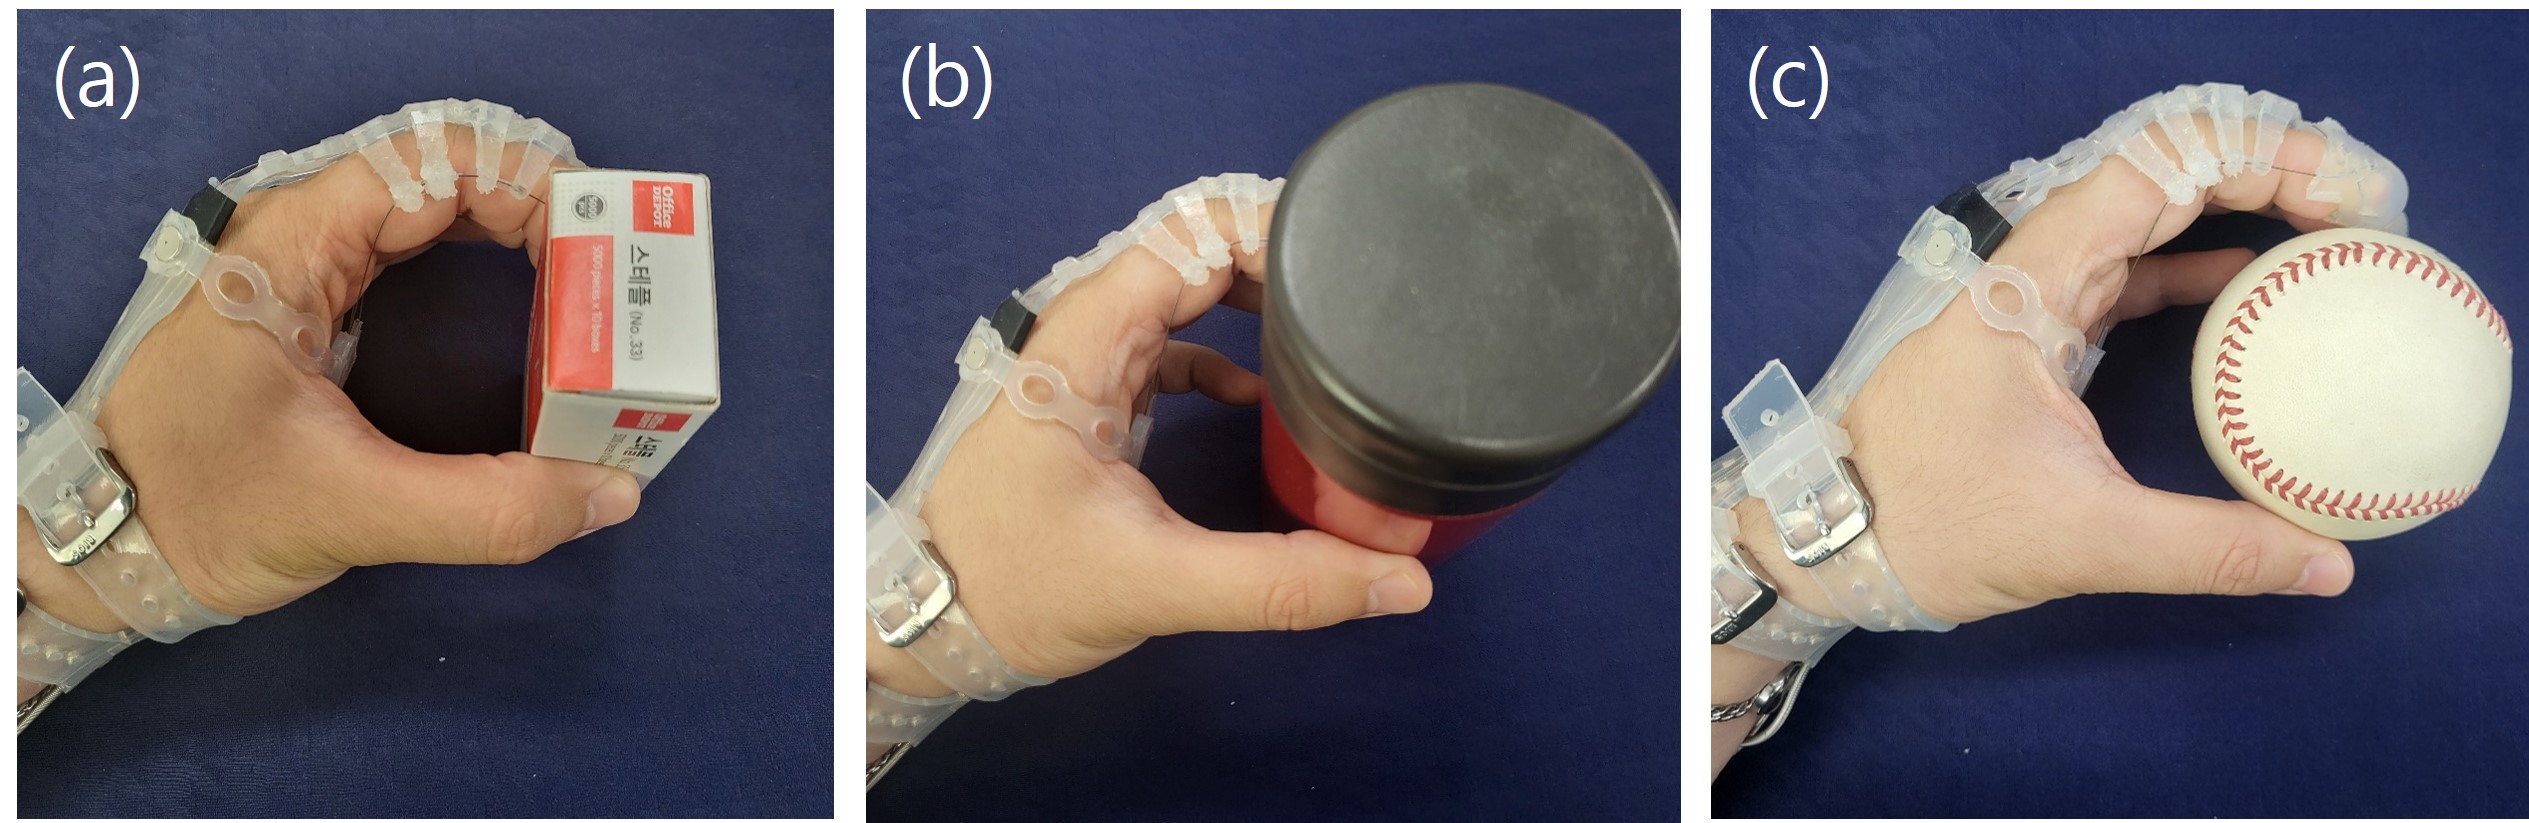
Following the adjustable test object, experiments used a box, bottle and baseball. Objects with different sizes and shapes were grasped repeatedly to compare estimates.
| Object | Dimension compared | Size |
|---|---|---|
| Box | Short side | 4.1 cm |
| Bottle | Diameter | 6.2 cm |
| Baseball | Diameter | 7.23 cm |